INTEGRATIONS
Sensors · Nav · Power · Comms
Open modular bays and SPEARHEAD software stack accept multi-mode sensors, GPS-denied navigation, hybrid power, and resilient multi-path communications.
INTEGRATIONS
Open modular bays and SPEARHEAD software stack accept multi-mode sensors, GPS-denied navigation, hybrid power, and resilient multi-path communications.
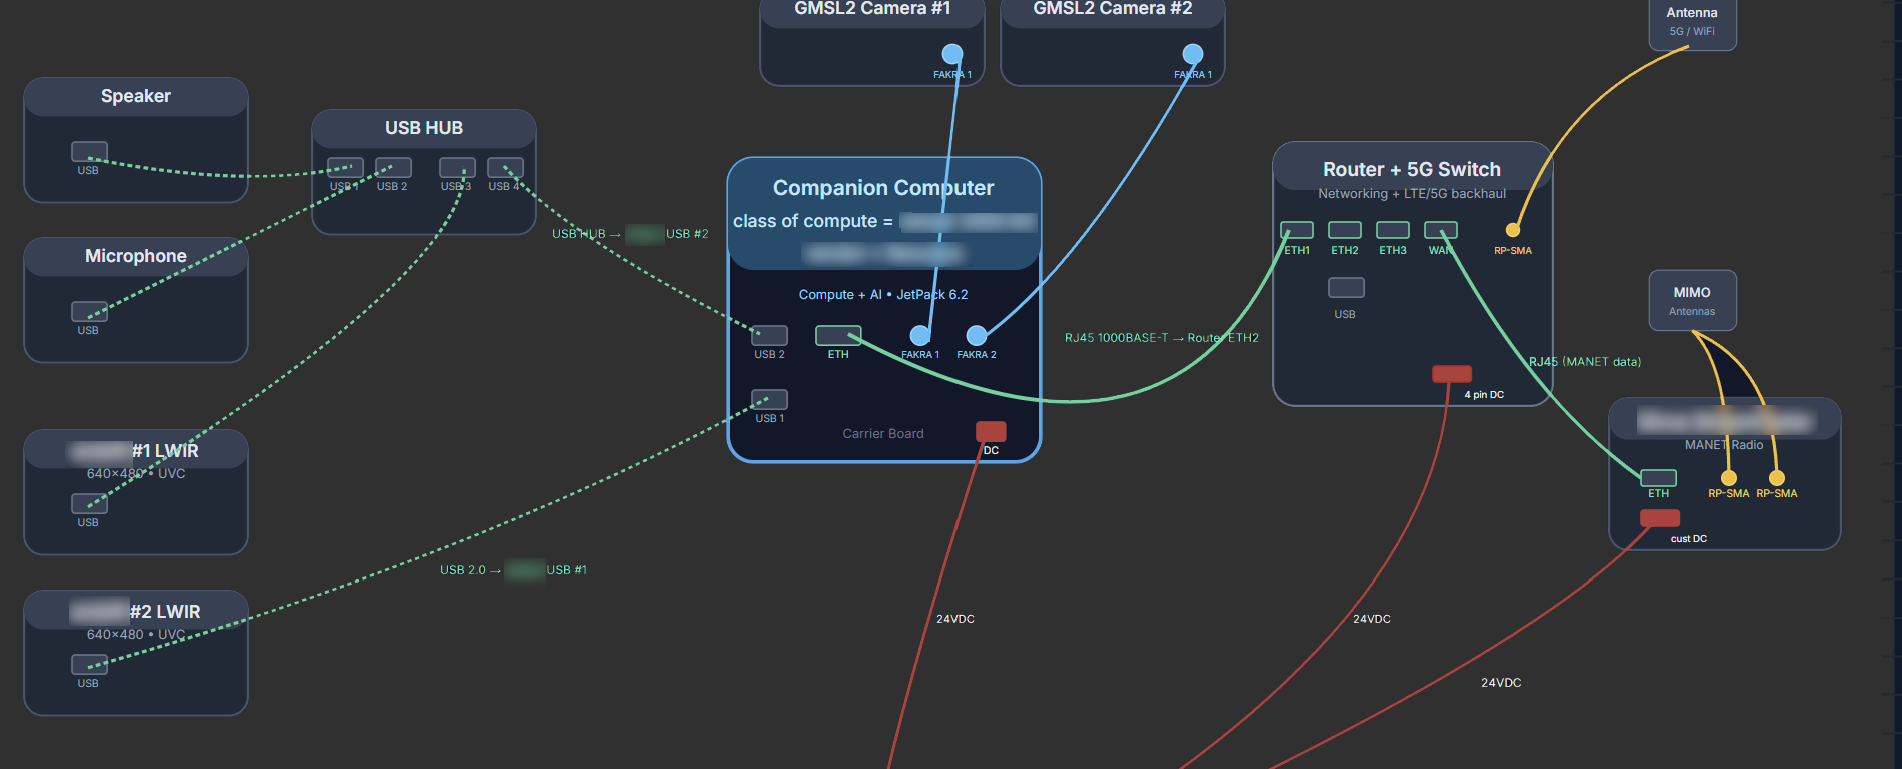
Onboard radar, EO/LWIR, SWIR, event/SNN cameras, laser designation, acoustics (onboard and dropped pucks), and full onboard sensor fusion with edge AI.
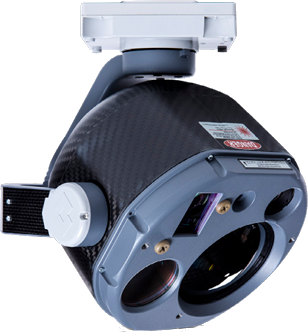
Teledyne FLIR StormCaster-DX class gimbals · day/night ISR-T
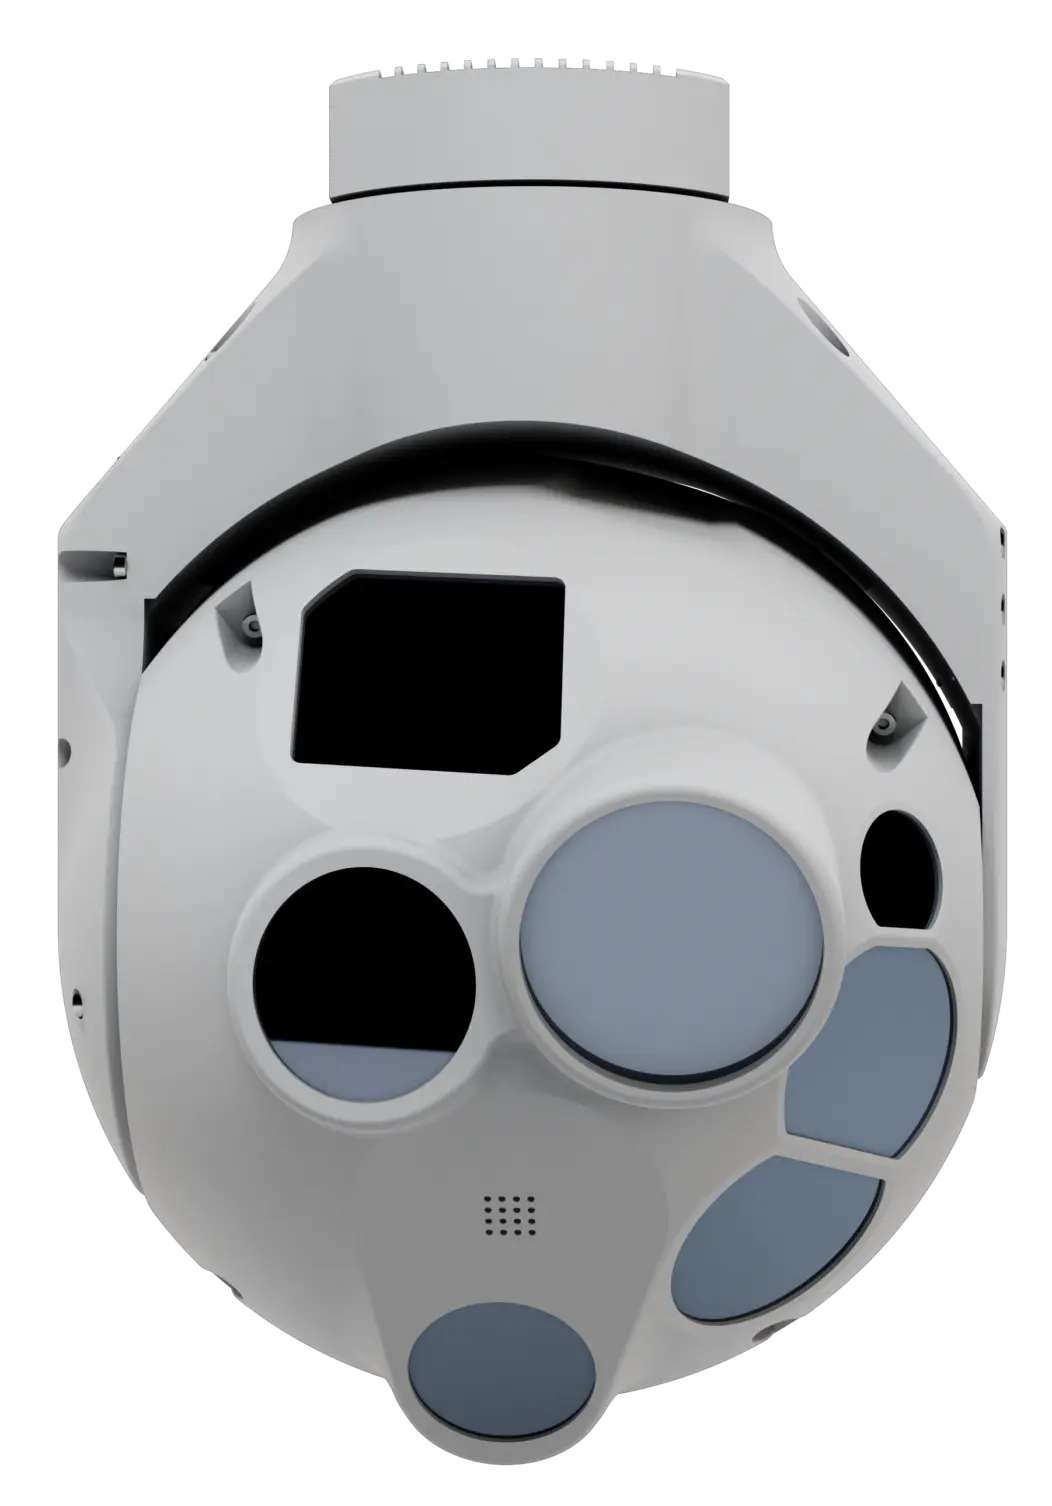
Trillium HD59 and similar · high-quality targeting payloads for HAMR
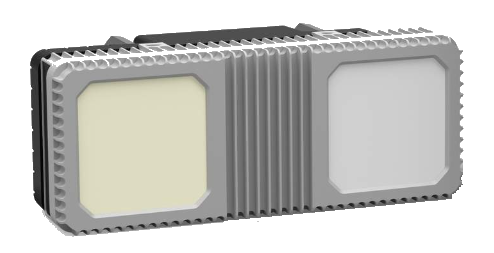
Fortem R20i class · Echodyne EchoFlight · CUAS detect/track · all-weather
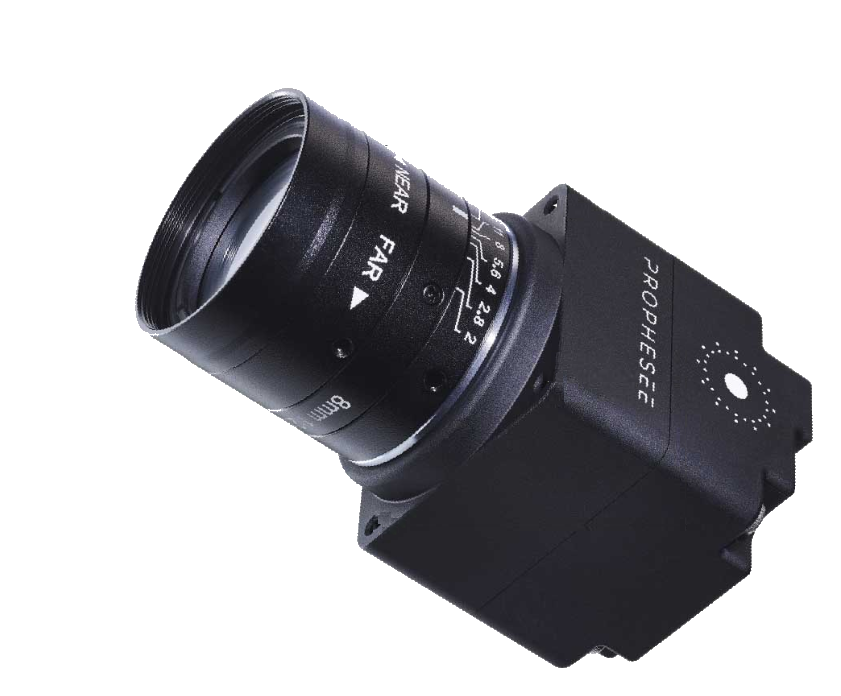
Prophesee / Sony IMX event sensors · high-speed detect/classify
2–18 GHz class RF sensing · SIGINT / CUAS RF detect
Onboard AI fusion · laser designator · acoustic pucks · SWIR
Event cameras and edge AI enable rapid classification of high-speed aerial threats for ZEVO terminal guidance packages.
Contested navigation is a SPEARHEAD baseline.
EO/LWIR + inertial + RF relative navigation for DDIL environments.
Military grade GPS which degrades to GPS-D when contested.
C2 guided navigation - FAAD control with cueing - for multiple missions (ISR-T, terminal engagement, and others).
Hybrid fuel-electric density on HAMR; high-energy battery packs on ZEVO; ground power delivery mission packages.
EFI computer-controlled piston engine + generator powering six independent electric motors. Remote in-flight engine start/restart using onboard batteries. Payload power: 200 W continuous / 2 kW peak @ 48 VDC.
ZEVO enables battery exchange for distributed forces and carries high-density packs for 30 km multi-mission flights. Land-and-power packages allow HAMR to act as a mobile edge power node for distributed forces.
Multi-path resilient networking for contested and expeditionary ops.
MANET
AES-256 encrypted mesh for unit and swarm networking.
MESH
Multi-thousand node networking for large formations.
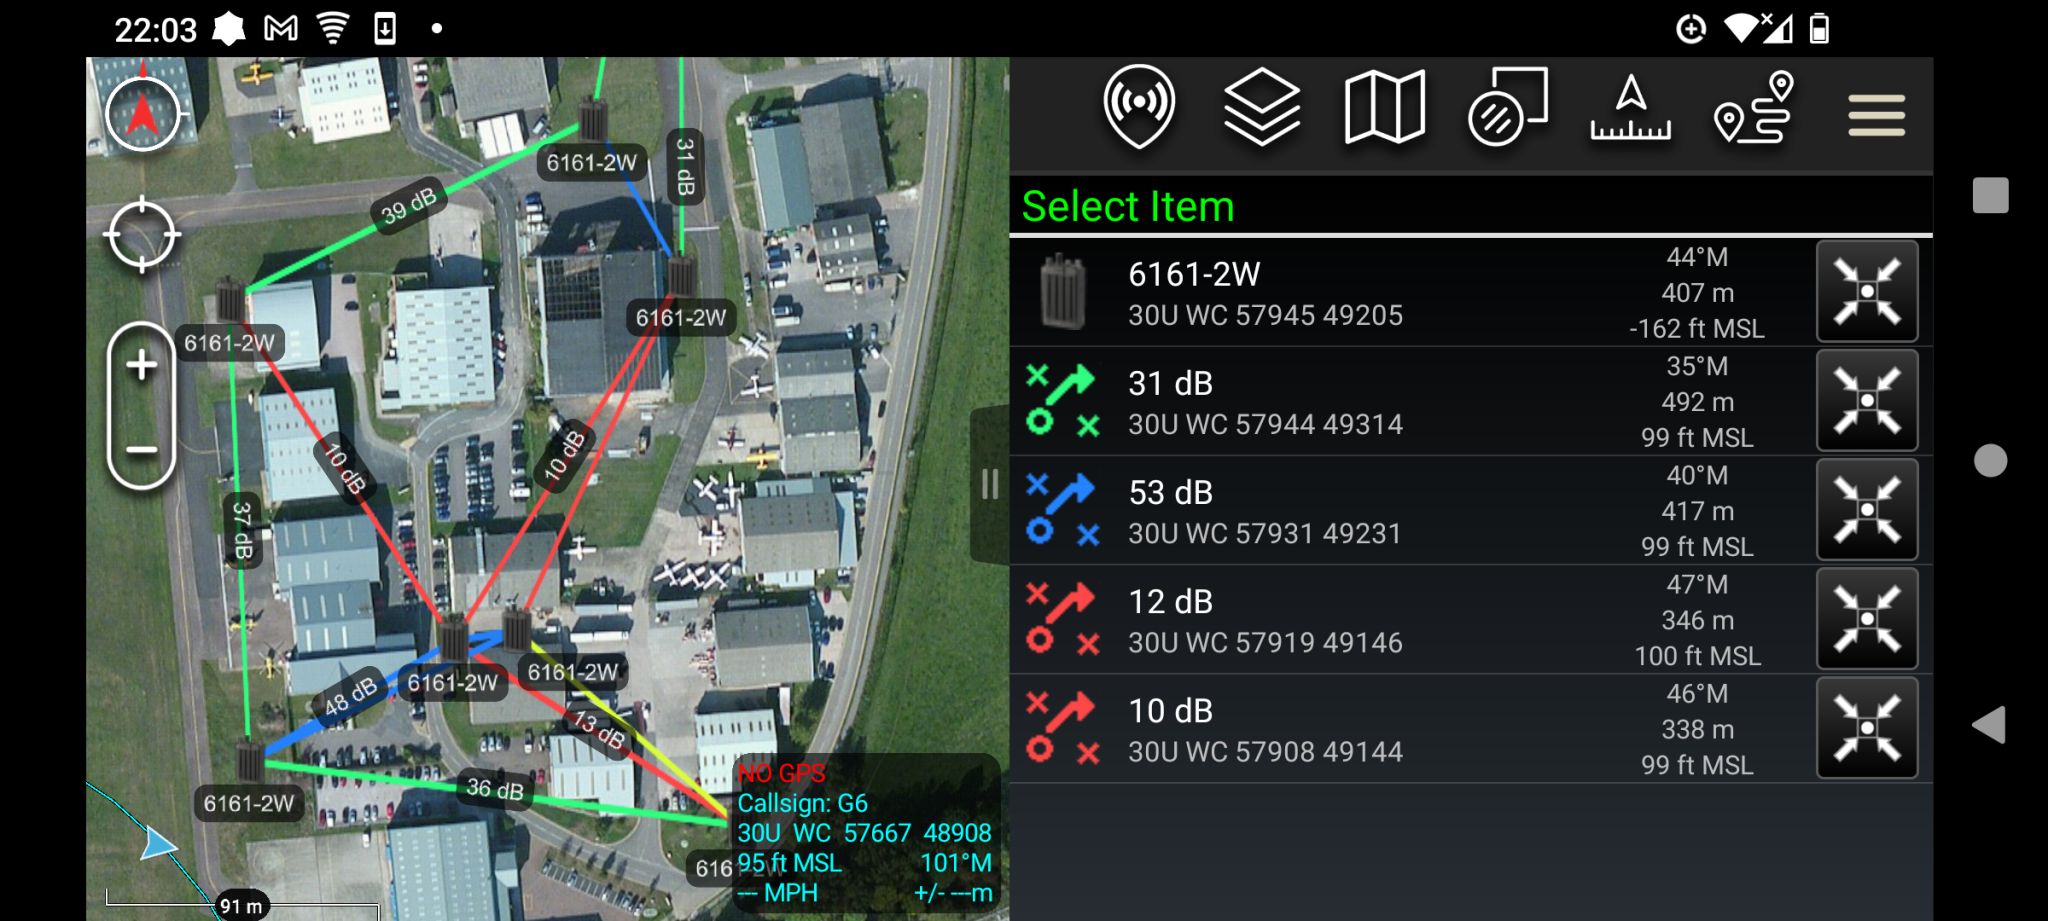
SPEARHEAD integrates with forward-area air defense and C2 systems for cueing, autonomy, and TAK/ATAK map interfaces — closing the loop from detect to defeat.